Overview
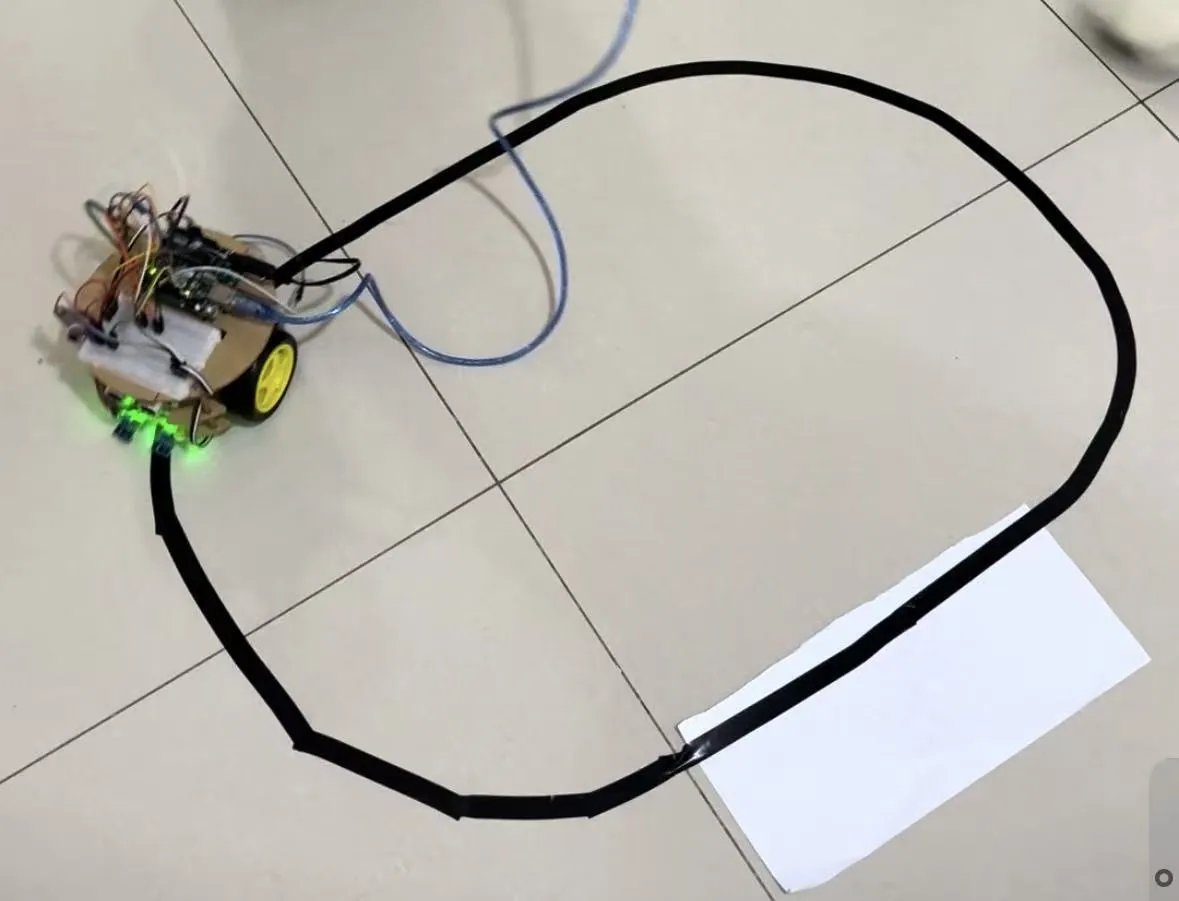
In the Robotics Workshop course, our team designed and built a line-following robot car using the Arduino IDE, going through the entire process from component selection and circuit wiring to programming and on-site testing.
My Role
My main responsibility was the code development and testing of the TCRT5000 infrared reflectance sensors. I wrote the data acquisition and black/white line threshold judgment programs, and calibrated the detection thresholds through repeated field tests — troubleshooting and solving misjudgment problems caused by ambient light interference, so that the car could finally track the black line stably and continuously.
What I Learned
This project was the first time I applied classroom programming and circuit knowledge to real hardware, and it taught me the weight of "test-driven" thinking in engineering: if a threshold is slightly off, the car goes off track; a piece of code is never truly done until it has passed real-world testing. Rigor and patience are what I gained most from this experience.